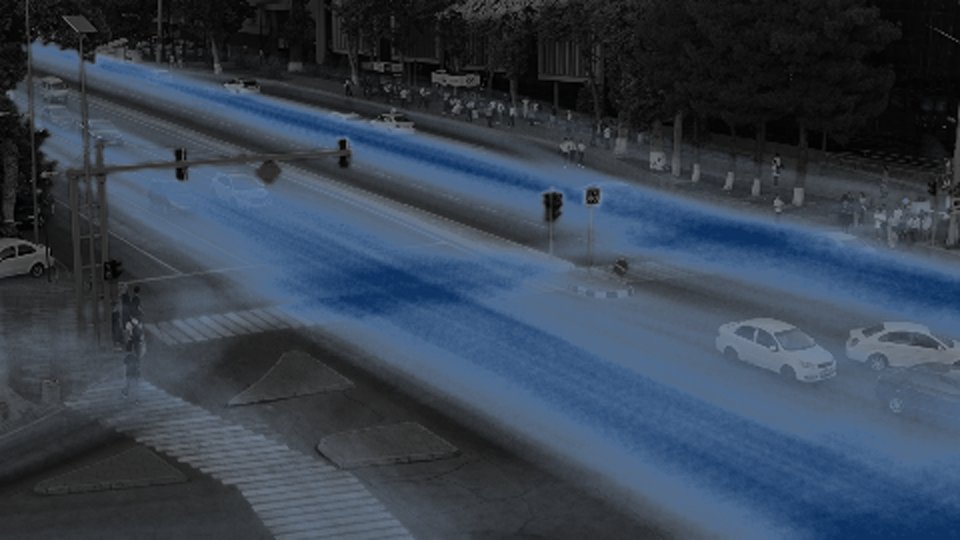
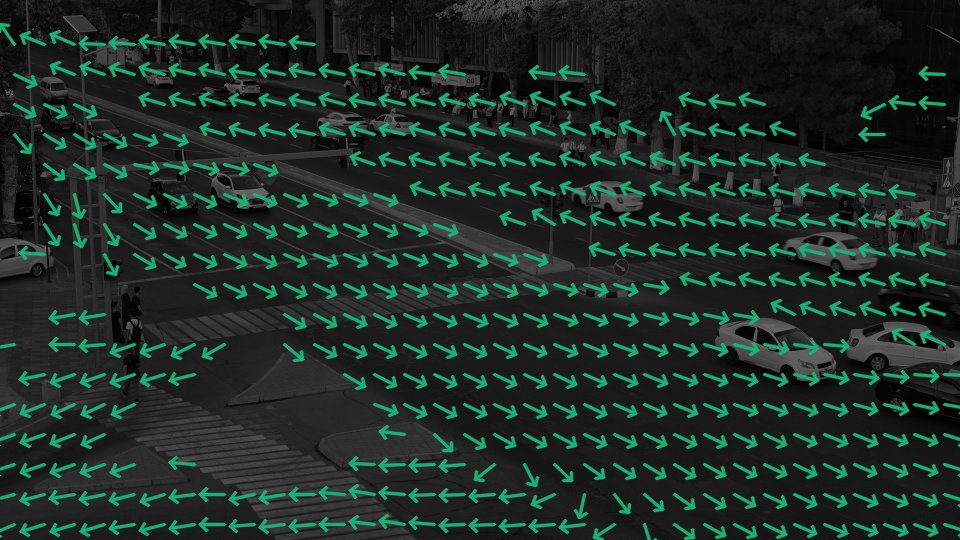
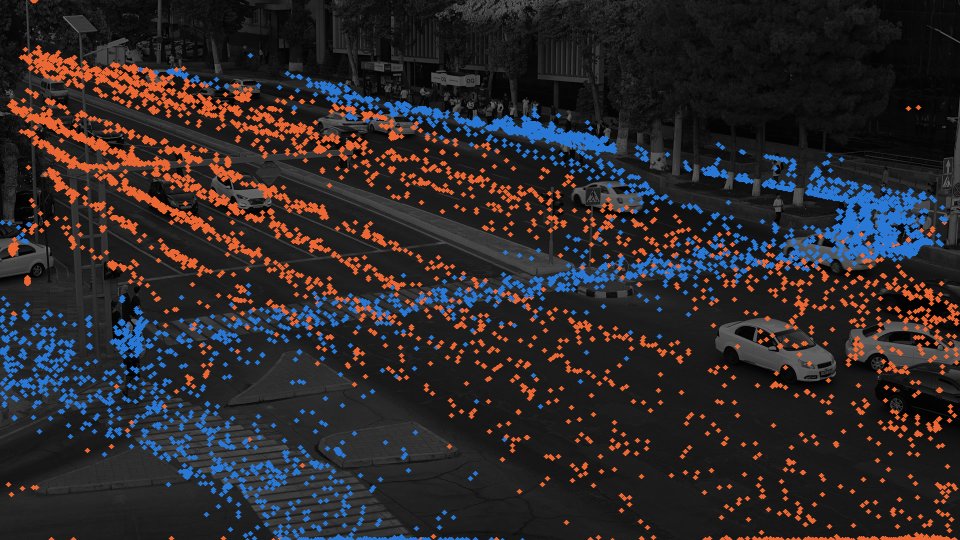
Sample result
C3902
- Resolution
- 3840 × 2160
- Frame rate
- 29.97 fps
- Length
- 5 min 18 s
- Frames
- 9,525
- Codec
- H264, 140 Mbit/s
- File
- C3902.MP4, 5.44 GB
Playback and event timeline
Click an event to seek. Where the model and our labels disagree, compare the two lanes directly.
Model predictions for this video are not exported yet
predictions_samples.json when the pipeline run completes.| Event | Label id | Start | End | Length |
|---|---|---|---|---|
| jaywalking | 0:03.0 | 0:04.0 | 1.0 s | |
| jaywalking | 0:06.0 | 0:15.0 | 9.0 s | |
| failure_to_yield | 0:12.0 | 0:13.0 | 1.0 s | |
| jaywalking | 0:19.0 | 0:38.0 | 19.0 s | |
| failure_to_yield | 0:23.0 | 0:27.0 | 4.0 s | |
| illegal_u_turn | 0:24.0 | 0:27.0 | 3.0 s | |
| jaywalking | 0:43.0 | 0:47.0 | 4.0 s | |
| jaywalking | 0:48.0 | 0:56.0 | 8.0 s | |
| failure_to_yield | 0:53.0 | 0:55.0 | 2.0 s | |
| jaywalking | 1:00.0 | 3:19.0 | 139.0 s | |
| solid_line_crossing | 1:03.0 | 1:04.0 | 1.0 s | |
| failure_to_yield | 1:28.0 | 1:36.0 | 8.0 s | |
| failure_to_yield | 2:12.0 | 2:14.0 | 2.0 s | |
| red_light | 2:35.0 | 2:36.0 | 1.0 s | |
| failure_to_yield | 2:51.0 | 2:52.0 | 1.0 s | |
| failure_to_yield | 2:54.0 | 2:55.0 | 1.0 s | |
| solid_line_crossing | 3:21.0 | 3:26.0 | 5.0 s | |
| solid_line_crossing | 3:32.0 | 3:36.0 | 4.0 s | |
| jaywalking | 3:39.0 | 3:45.0 | 6.0 s | |
| jaywalking | 3:47.0 | 3:49.0 | 2.0 s | |
| jaywalking | 3:57.0 | 4:01.0 | 4.0 s | |
| failure_to_yield | 4:03.0 | 4:04.0 | 1.0 s | |
| solid_line_crossing | 4:03.0 | 4:13.0 | 10.0 s | |
| jaywalking | 4:08.0 | 4:30.0 | 22.0 s | |
| jaywalking | 4:32.0 | 4:35.0 | 3.0 s | |
| jaywalking | 4:37.0 | 4:56.0 | 19.0 s | |
| illegal_turn | 4:44.0 | 4:50.0 | 6.0 s | |
| failure_to_yield | 4:48.0 | 4:50.0 | 2.0 s | |
| stop_line | 5:16.0 | 5:17.0 | 1.0 s |
Dev labels: Team-reviewed event intervals; overlapping same-class intervals merged for evaluation.
Failure cases
Where the output is wrong on this clip and why. Stated plainly so the gaps are visible.
Not reviewed yet
EDA for this clip
Road users over time
Detections per frame every 2 s (fixed_names.pt, 1280 px, confidence ≥ 0.25). Counts are detections, not unique objects. Click a name to hide it.
Traffic-signal phases
Seconds where the detector saw a red or green signal head. Several heads are visible at once, so both rows can be on together. This is what red_light and stop_line rules key on.
Lighting
Mean frame brightness (luma, 0–255).
Motion
Share of the image that changed between frames (frame differencing, ~10 fps).